
Egocentric human demonstrations
Continuous first-person demonstrations capturing hands, tools, objects and surrounding workspace context.
RGBIMUAudio where configuredTimestampsCalibration metadata
DATRAAI / REAL-WORLD DATA INFRASTRUCTURE
DatraAI designs and operates custom data programs for robotics, world-model and embodied-AI teams—capturing egocentric, stereo, UMI-style and teleoperation data, then delivering raw, synchronized or training-ready episodes.
Define the tasks, environments, sensors, embodiment, volume and acceptance criteria. We design the pilot around them.
Backed by
 Founders, Inc.
 The Residency
 Inception program
Program and investor affiliations shown for company context; they are not presented as customer relationships.
01 / Multimodal Data
You define the tasks, environments, modalities, geography, volume, output format and acceptance criteria. DatraAI designs the capture configuration, operates the data program, validates each session and delivers the required package.
Continuous first-person demonstrations capturing hands, tools, objects and surrounding workspace context.
Synchronized dual-view global-shutter capture for geometry-aware human activity and manipulation datasets. The stereo signal supports downstream geometry and disparity processing.
UMI-style and gripper-based collection for contact-rich manipulation, including device pose, gripper state, visual context and tactile information where configured.
Robot observations, state and actions captured during human-controlled execution, scoped to the customer’s target embodiment and task set.
Available delivery levels
Original video, IMU, audio, pose, tactile and robot streams with associated metadata.
Time-aligned streams, calibration, session manifests and quality reports.
Structured episodes packaged through Actuate into LeRobot, RLDS, canonical or agreed customer formats.
EnvironmentsPrograms can be scoped for commercial kitchens, hospitality, retail, warehousing, manufacturing, agriculture, home, office and laboratory environments.
02 / Hardware
DatraAI deploys lightweight egocentric wearables, synchronized stereo systems and portable manipulation rigs. The final hardware configuration is matched to the task, operator, environment and required output.
Configurations shown are representative systems available through DatraAI data programs. Exact configuration and availability are confirmed during scoping.
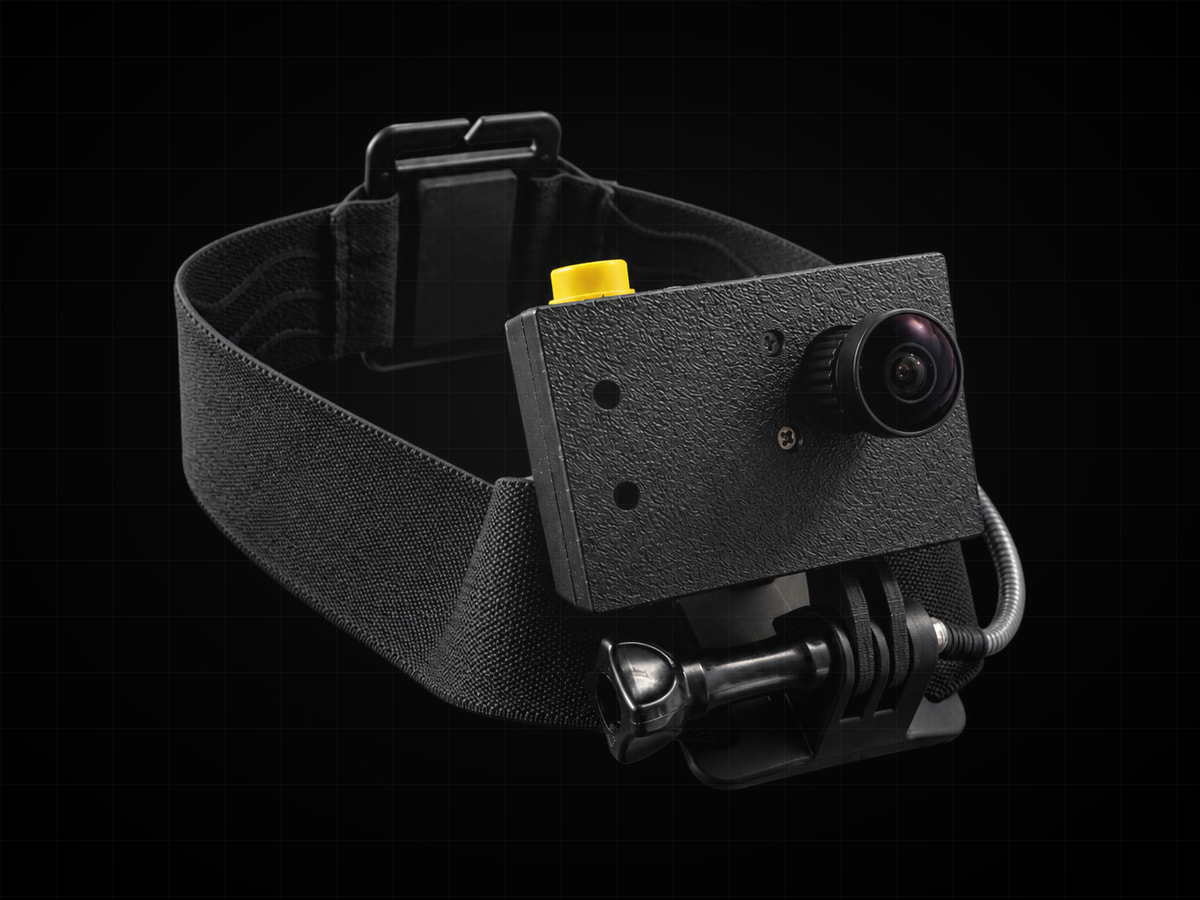 01 / CAPTURE SYSTEM
Field-ready RGB + IMU
Best for scalable first-person human activity and manipulation capture.
A 30 g head-mounted camera module recording wide-field first-person RGB with tightly synchronized 9-DOF motion sensing. It supports live app-connected capture and standalone field recording.
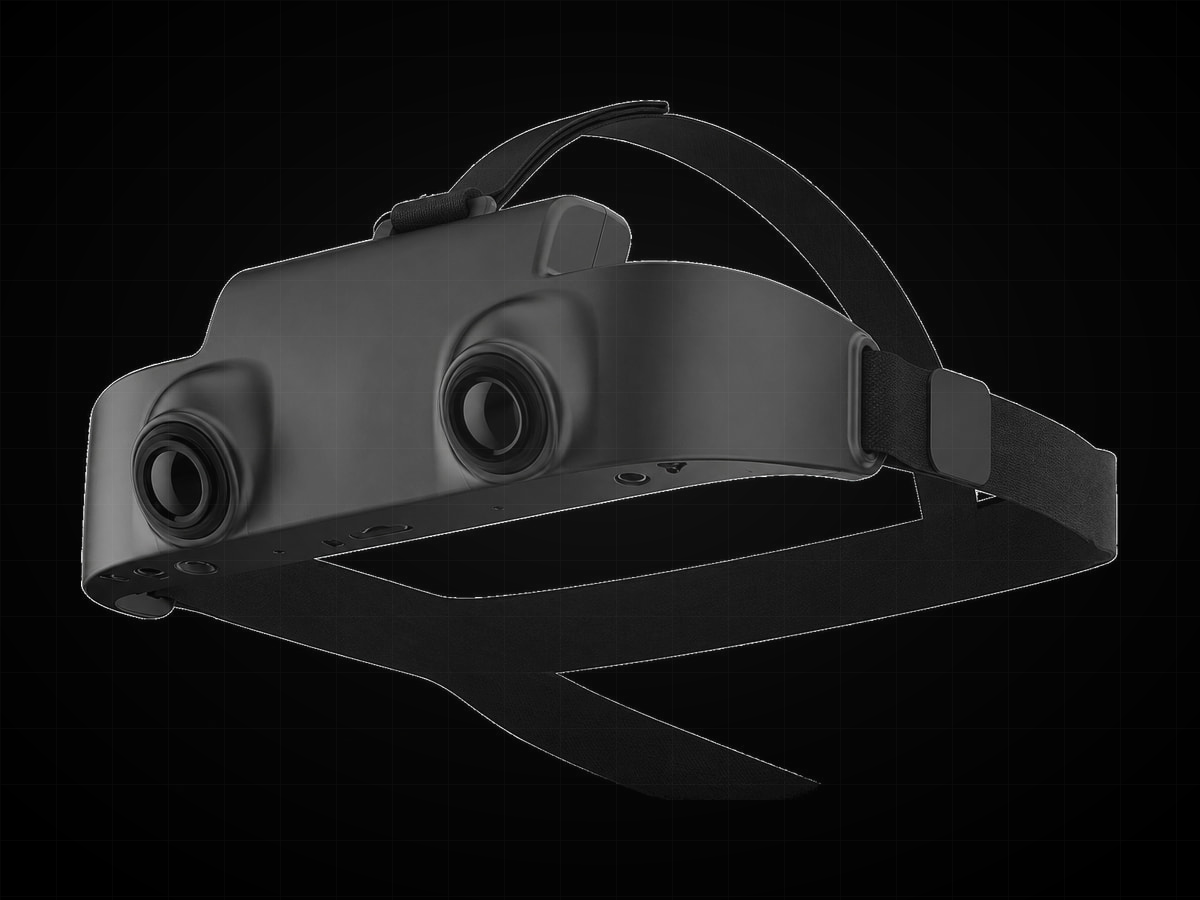 02 / CAPTURE SYSTEM
Global-shutter dual RGB + IMU
Best for synchronized dual-view activity capture and geometry-aware datasets.
A lightweight binocular capture headset combining two synchronized global-shutter RGB cameras, high-rate IMU sensing, local storage, audio and wireless or wired data transfer.
 03 / CAPTURE SYSTEM
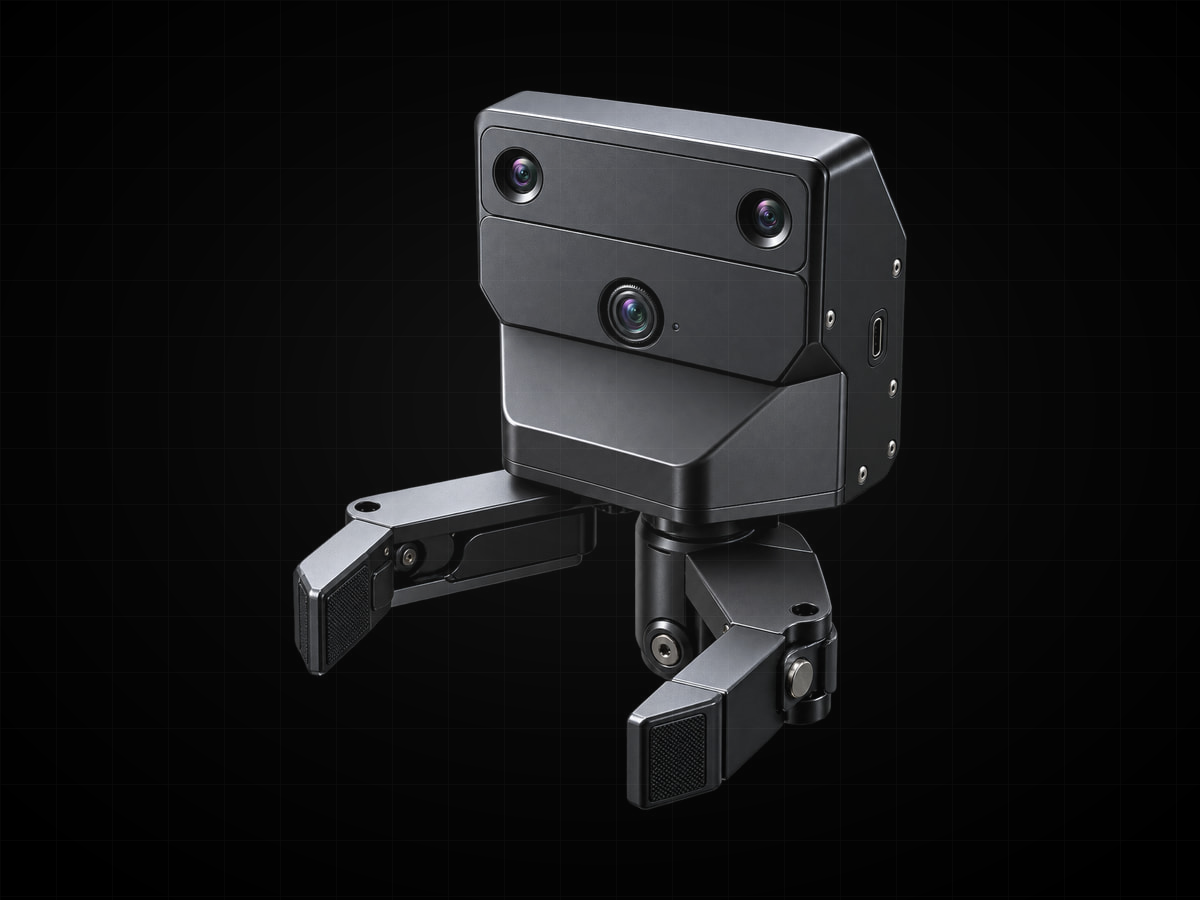
Pose + gripper + tactile + RGB
Best for contact-rich, in-the-wild manipulation demonstrations.
A portable UMI-style capture system combining global-shutter visual sensing, visual-inertial pose estimation, gripper-state detection and high-resolution visuotactile force sensing.
03 / Actuate
Actuate is DatraAI’s multimodal processing and quality layer. It verifies capture inputs, aligns sensor streams, recovers task structure, records provenance, applies quality and privacy gates, and packages usable episodes for the customer’s training stack.
Confirm the declared rig, channels, metadata and session integrity.
Align video, IMU, audio, pose, tactile and robot streams onto a shared timeline.
Recover hands, objects, depth, task intervals and action structure where supported.
Map heterogeneous capture systems into a consistent, versioned episode representation.
Record data quality, processing status, provenance, consent and privacy results.
Deliver LeRobot, RLDS, canonical or agreed customer schemas.
Engagement / Pilot to Scale
A representative pilot establishes the capture configuration, quality bar and delivery structure before a program expands.
Share the target tasks, environments, modalities, embodiment, volume, output format and acceptance criteria.
DatraAI selects the capture configuration and runs a representative evaluation batch.
Your team reviews the signal quality, task coverage, schema and downstream usability before scale-up.
Collection expands through a documented operating plan, recurring quality checks and agreed delivery schedule.
04 / Research
DatraAI studies how capture quality, multimodal alignment and physical representations affect learning from real interaction data. Research results, benchmarks and technical reports are published as they become ready.
Developing measurable links between capture quality, distribution coverage and downstream model performance.
Aligning RGB, stereo, depth, IMU, pose, tactile and robot signals into consistent representations of physical interaction.
Exploring action-conditioned prediction and physical-world learning from real human and robot interaction data.