Hardware / Capture Systems

Capture systems selected for the signal your model needs.

DatraAI deploys lightweight egocentric wearables, synchronized stereo systems and portable manipulation rigs through custom data programs. Selection depends on the target task, operator, environment and required outputs.

Representative configurations

Hardware available through a DatraAI data program.

Configurations shown are representative. Exact specifications, configuration and availability are confirmed during scoping; this page does not claim that DatraAI manufactures each device.

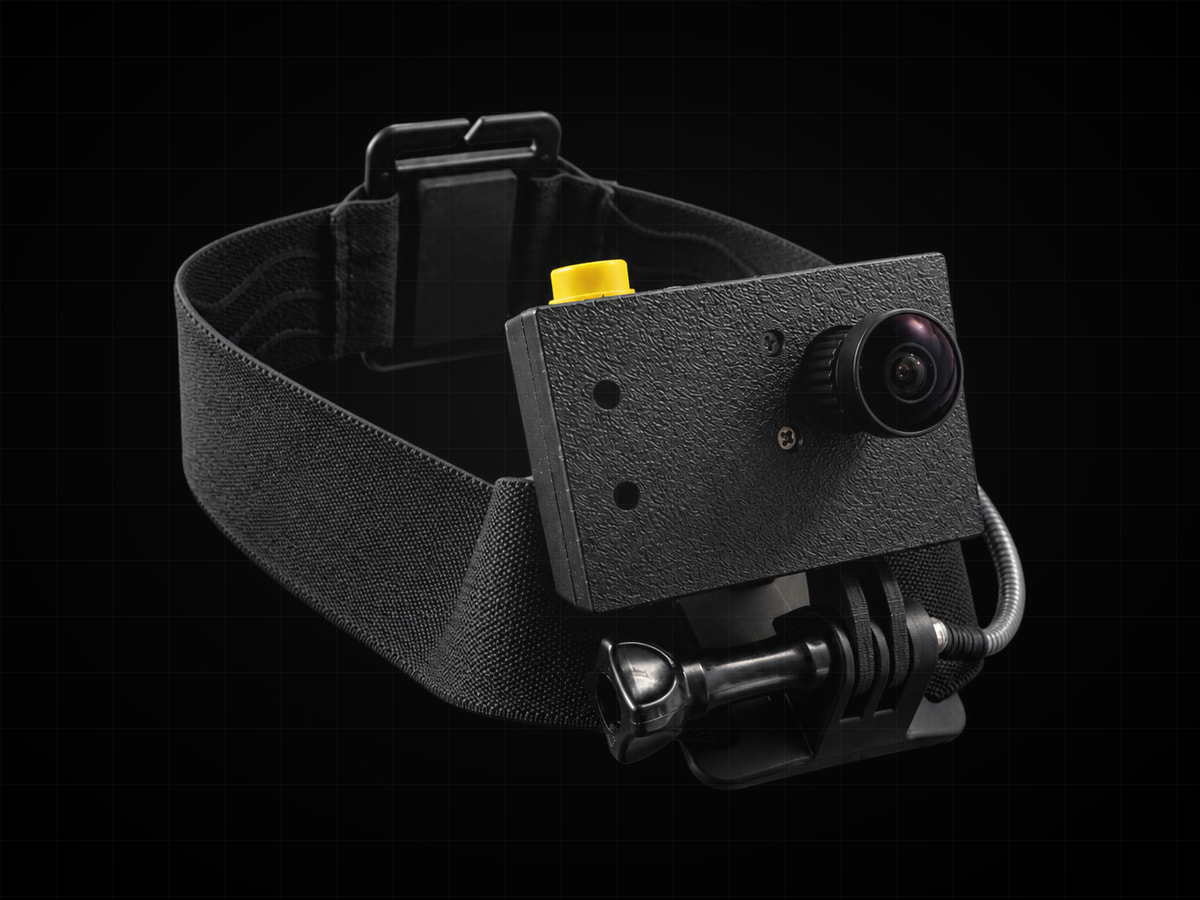
Lightweight monocular egocentric camera used for first-person data collection01 / CAPTURE SYSTEM

Field-ready RGB + IMU

Monocular egocentric wearable

Best for scalable first-person human activity and manipulation capture.

A 30 g head-mounted camera module recording wide-field first-person RGB with tightly synchronized 9-DOF motion sensing. It supports live app-connected capture and standalone field recording.

Key specifications

  • Recording: 1920 × 1080 at 30 FPS
  • Horizontal field of view: 180°
  • Motion sensing: 9-DOF IMU at 562.5 Hz
  • IMU-frame synchronization delay: <1 ms
  • Camera module weight: 30 g, excluding head strap
  • Capture modes: live USB/UVC streaming or standalone recording
  • Interface: USB-C / UVC
  • Local storage: removable SD card, up to 2 TB
  • Power: external power bank; up to 9 hours with the referenced 2,500 mAh configuration

Outputs

RGB video9-DOF IMUTimestampsCalibrationSession metadata
Technical details
  • Sensor: 3 MP CMOS
  • Encoding: H.264; H.265 and MJPEG supported
  • Container: MP4 with .imu and .vts sidecar data
  • Pixel format: YUVJ 4:2:0, BT.709
  • Mount: action-camera compatible; head mount supported
  • Android UVC SDK available
  • Data inspection and validation tooling
  • Camera calibration tooling
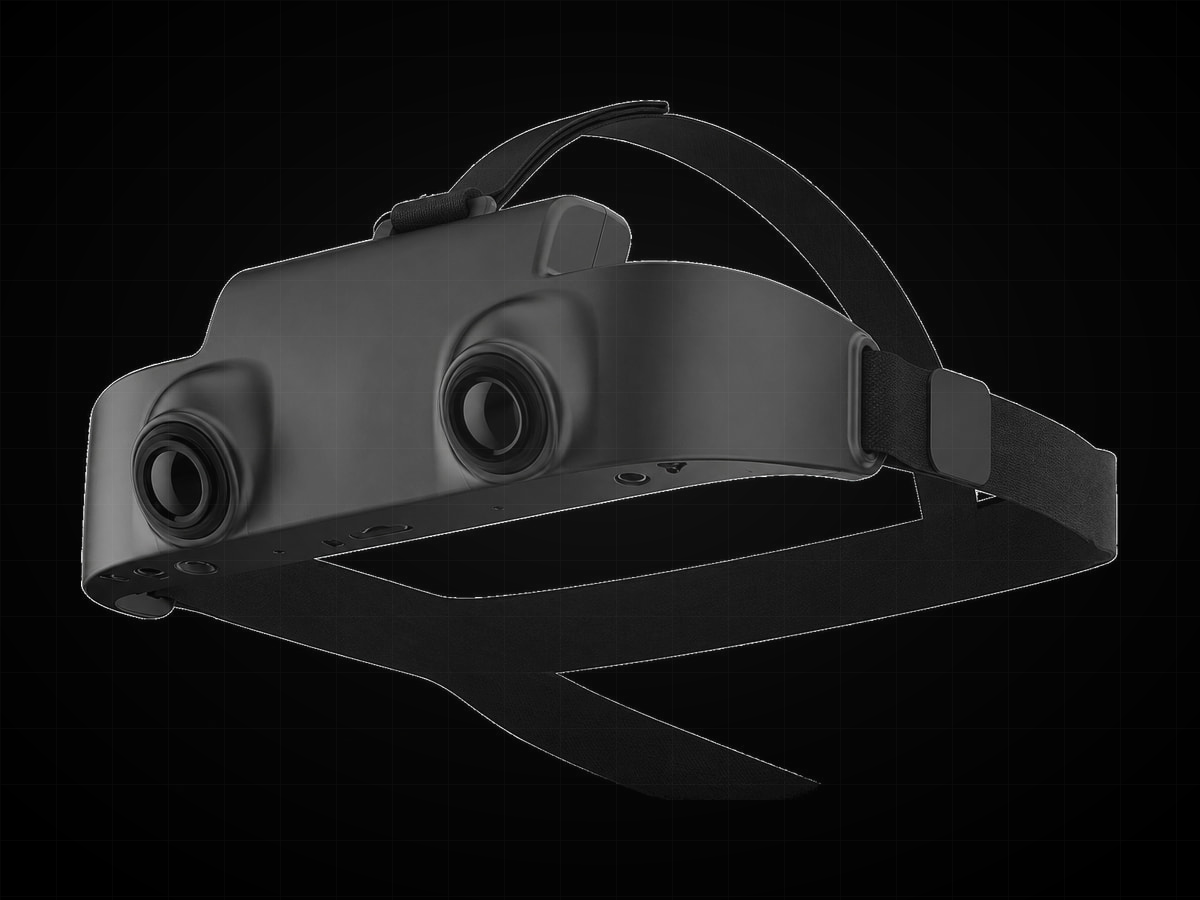
Global-shutter stereo egocentric headset used for synchronized dual-view collection02 / CAPTURE SYSTEM

Global-shutter dual RGB + IMU

Stereo egocentric wearable

Best for synchronized dual-view activity capture and geometry-aware datasets.

A lightweight binocular capture headset combining two synchronized global-shutter RGB cameras, high-rate IMU sensing, local storage, audio and wireless or wired data transfer.

Key specifications

  • Camera system: 2 × RGB global-shutter cameras
  • Recording: up to 1080p at 60 FPS
  • Stereo baseline: 65 mm
  • Field of view: up to 194° horizontal × 111° vertical per camera
  • IMU sampling: up to 1 kHz
  • Device weight: <150 g for the referenced configuration
  • Battery runtime: >5 hours for the referenced built-in battery configuration
  • Storage: removable MicroSD
  • Connectivity: Wi-Fi 6, Bluetooth 5.4 and USB
  • Audio: microphone capture supported

Outputs

Left RGBRight RGBHigh-rate IMUAudioTimestampsCamera intrinsicsCamera extrinsics
Technical details
  • Processor: dual-core, up to 1.0 GHz
  • Built-in battery: 1,600 mAh in the referenced configuration
  • External power bank supported
  • Colour video: MP4 / H.265
  • Independent image output supported
  • Wired USB upload
  • Wireless Wi-Fi upload
  • Linux-based system
  • Open data interface available for integration
  • Hardware output is synchronized stereo RGB; depth or geometry is computed downstream only when the relevant processing path is validated.
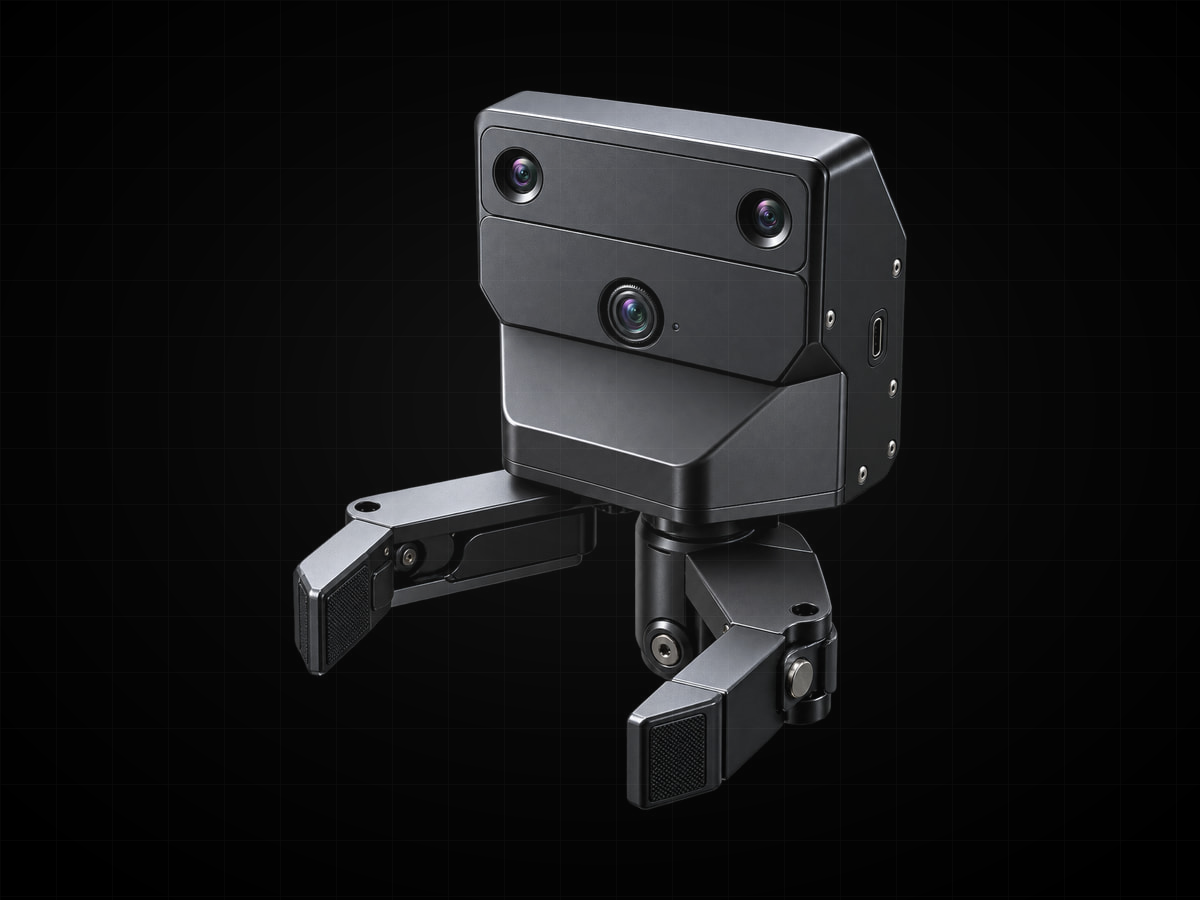
Portable visuotactile manipulation gripper used for UMI-style data collection03 / CAPTURE SYSTEM

Pose + gripper + tactile + RGB

Portable visuotactile manipulation rig

Best for contact-rich, in-the-wild manipulation demonstrations.

A portable UMI-style capture system combining global-shutter visual sensing, visual-inertial pose estimation, gripper-state detection and high-resolution visuotactile force sensing.

Key specifications

  • Vision: global-shutter RGB camera
  • Vision field of view: 160°
  • Frame rate: 30 FPS
  • Localization: visual-inertial odometry using stereo fisheye cameras and IMU
  • Tactile system: 2 × visuotactile sensors
  • Tactile output: 3D force at 30 FPS
  • Tactile resolution: up to 60,000 sensing points in the referenced configuration
  • Stated tactile error: <5%
  • Gripper-opening detection: magnetic encoder
  • Position localization error: ≤3 mm in the referenced loop-closure test
  • Attitude localization error: ≤0.3° in the referenced loop-closure test
  • Time-synchronization error: ≤30 ms
  • Continuous operation: ≥2 hours
  • Backpack weight: 2.5 kg
  • Output compatibility: LeRobot-compatible data format

Outputs

RGBDevice poseGripper opening3D tactile forceIMU / VIOTimestampsCalibration
Technical details
  • Host platform: i5-1235U-class system
  • Referenced memory/storage configuration: 8 GB + 128 GB
  • Built-in 12 V battery
  • External 12 V DC charging
  • On-device tactile processing
  • Edge-side pose estimation
  • One-button recording, standby and initialization
  • One-handed capture workflow
  • Replaceable battery support where configured
  • Desktop, indoor and outdoor collection use

Choose by target signal, not by a universal ranking.

Each system preserves a different combination of context, geometry, motion and contact. Selection depends on the target task and downstream use.

SystemPrimary valuePrimary signalsBest fit
Monocular wearableWide-context, low-burden, scalable human captureRGB + synchronized IMUHigh-volume first-person activity
Stereo wearableSynchronized dual-view captureDual global-shutter RGB + high-rate IMUGeometry-aware collection
Visuotactile gripperContact-rich manipulation capturePose + opening + tactile + RGBUMI-style manipulation demonstrations

Stereo hardware records synchronized dual RGB and calibration signals. Depth or geometry may be computed downstream only when the relevant processing path has been validated for the program.